Technical route
Six-Axis Robot Systems
Evaluate articulated robot cells for CNC machine tending, defined part transfer and handling sequences that need changes in orientation.
Start with the movement your process needs.
A six-axis robot can approach a part from several directions and move between defined stations. That flexibility is useful only when the complete cell can present, grip and locate parts reliably.
Key selection inputs
- Workpiece and gripper mass, center of gravity and inertia
- Reach across all pick, place and service positions
- Required orientations, collision clearances and cable routing
- Part presentation, workholding and operator access
A robot’s catalogue payload does not by itself define a suitable cell. Gripper loading, reach, speed, protection requirements and the operating environment need review.
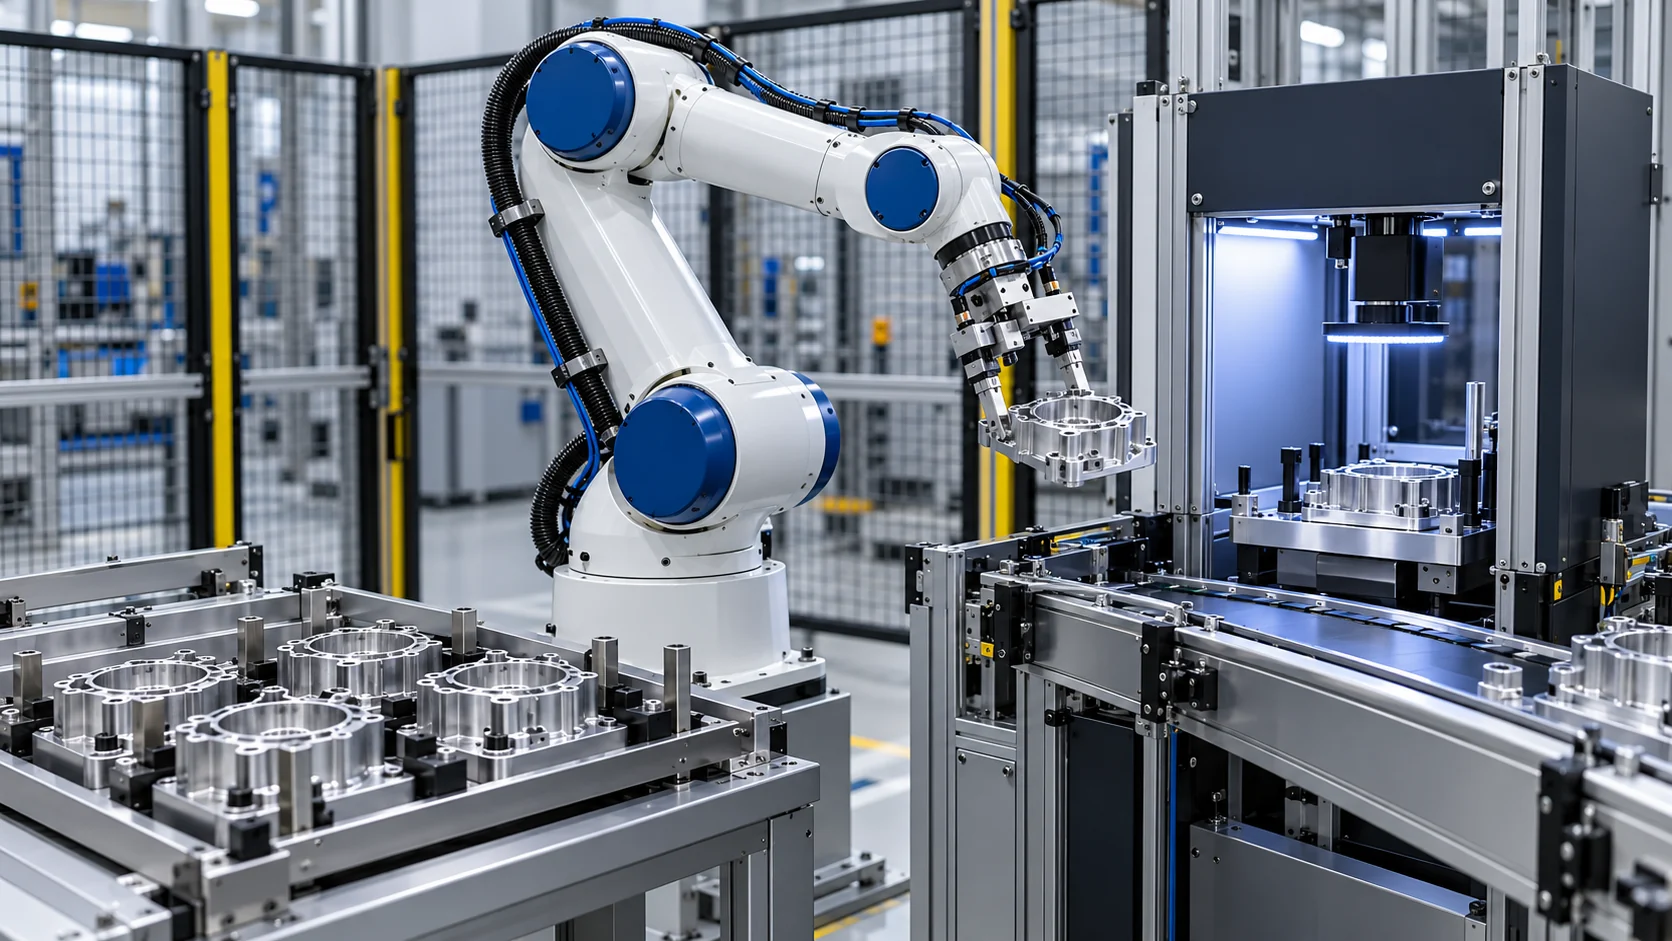 AI-generated application concept
Tell us about the process.
We’ll explore the right automation.
Start with your part drawing, machine model or a short process video.